DYNAMICS LAB · ENGINE01
Comparing flight trajectory models
All models are compared on the same nine held-out civil flights. The charts show how errors differ and how often observations fall within the estimated uncertainty regions.
Go to flight playback ↓Compare the nine recorded flights
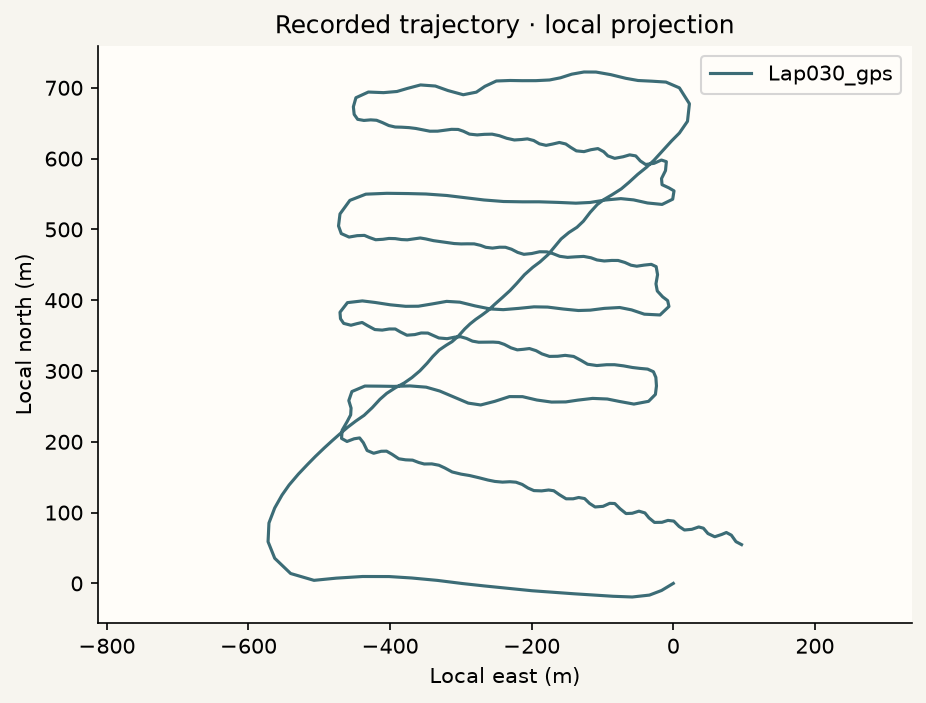
The chart compares nine flights recorded with the same drone. Select a flight to highlight it and see its GPS coordinates and model results.
- Highlighted flight: Lap030
- Other 8 flights
Test flight 9 · Lap030 · 8:55
- Aircraft used
- Volantex Ranger 2400 · SpeedyBee F405 / INAV
- Model with the lowest mean error
- Kalman filter · 10.43 m
- GPS position at the selected time
- Latitude 39.299810° · Longitude -0.611382°
All models tested
The six models and their ensemble were compared with observed GPS positions at 1, 3 and 5 seconds. Results apply to the selected flight.
| Model | Mean error (ADE) | Root mean square error (RMSE) |
|---|---|---|
| Kalman filter (KF) | 10.43 m | 17.56 m |
| Correlated random walk (CRW) | 10.68 m | 17.21 m |
| Model ensemble (ENSEMBLE) | 10.81 m | 16.81 m |
| Constant velocity (CV) | 14.31 m | 23.52 m |
| Constant acceleration (CA) | 20.30 m | 31.66 m |
| Random walk (RW) | 31.36 m | 38.98 m |
| Ornstein–Uhlenbeck (OU) | 184.66 m | 212.40 m |
The tracks share a geographic reference. Playback is accelerated. WGS84 coordinates come from the original GPS samples shown in the chart.
DME-001
Experiment conclusions
On nine test flights, Kalman had the lowest mean displacement error at 9.12 m, slightly ahead of CRW at 9.27 m. The ensemble had the lowest RMSE, 15.12 m, while its mean error was 9.60 m. Model choice therefore depends on the error measure that matters.
Study limits. The flights share a platform and circuit. GNSS is a noisy reference and the ranking may differ on other flights.
Model-by-model results
- RW
- Random-walk reference: 34.80 m mean error, above constant velocity.
- CV
- Constant velocity: 12.74 m mean error, a useful simple baseline.
- CA
- Constant acceleration: 18.13 m mean error, above CV in this test.
- KF
- Kalman: lowest mean error, 9.12 m.
- CRW
- Correlated random walk: 9.27 m mean error, close to Kalman.
- OU
- Ornstein–Uhlenbeck: highest mean error, 180.27 m. High coverage did not offset poor accuracy.
- Ensemble
- Model combination: lowest RMSE, 15.12 m.
- HMM
- Groups motion patterns into descriptive states. The states have no verified intent labels.
- EKF
- Extended Kalman filter: available in the core, without a measured result in DME-001.
- Particle Filter
- Available in the core, without a measured result in DME-001.
- Monte Carlo
- In DME-003, 100 synthetic random-walk replicates produced a distribution of final outcomes.
DME-001 · Real experimental data
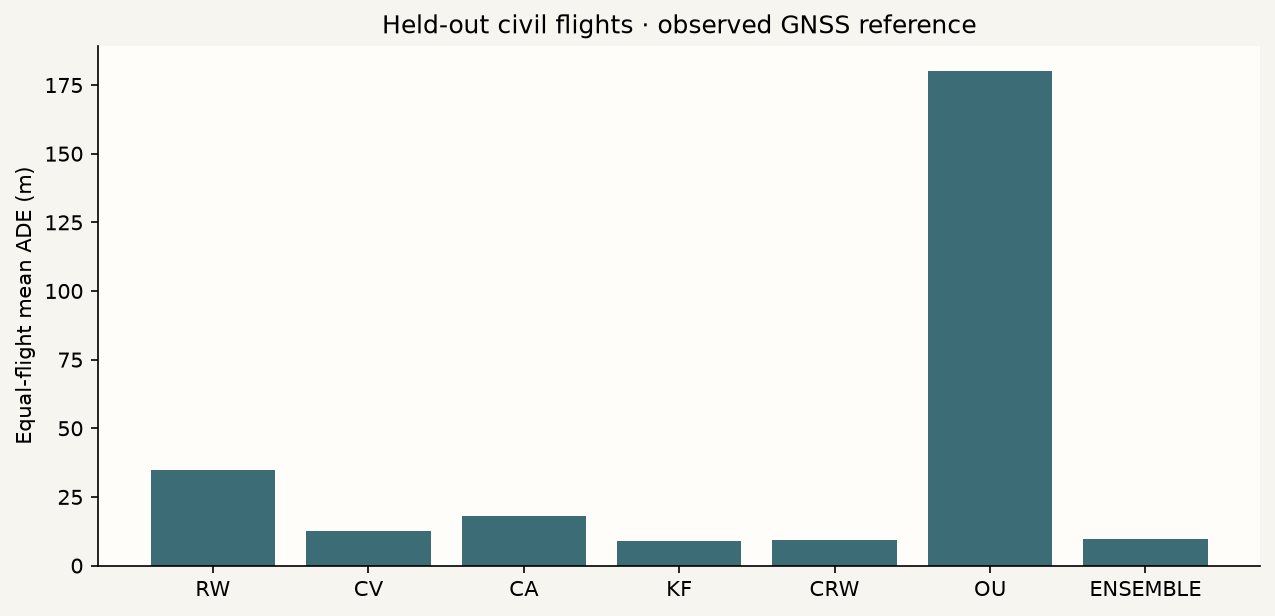
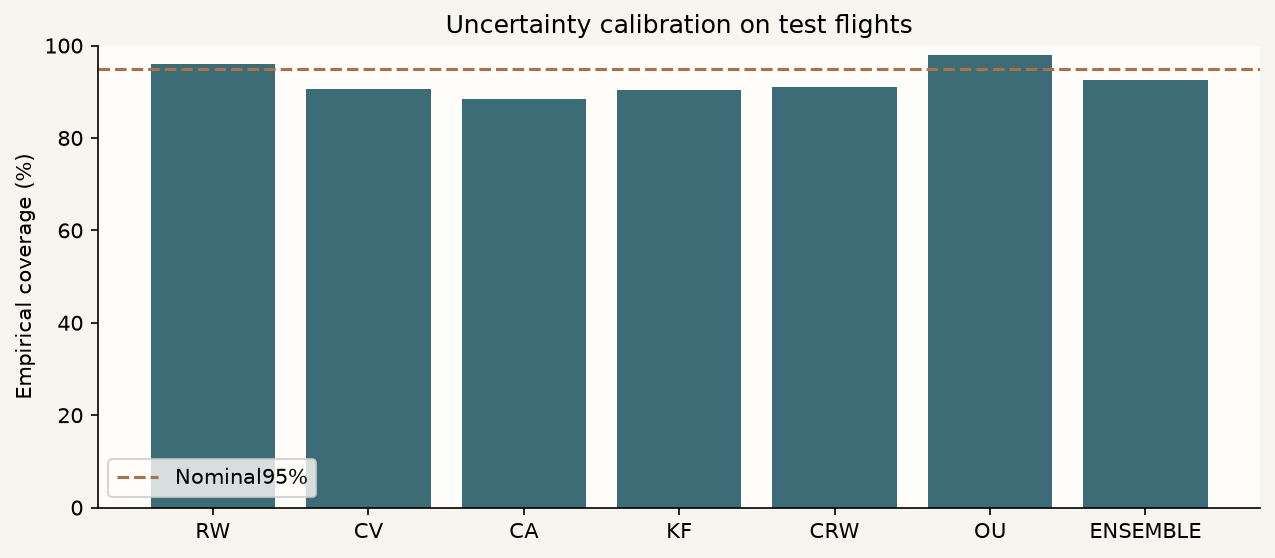
The uncertainty intervals were estimated by resampling whole flights. The flights share an aircraft and circuit, and the recording dates are unknown, which limits independence. The comparison tests whether more complex models offer an advantage.
Data and technical files
- Download results (JSON)
- Download the manifest (JSON)
- Download details (JSON)
- Download method and instructions (text)
The technical details below contain the study tables and limitations. The original data and instructions are available to download.
Technical details and reproducibility
Study context
- Problem addressed
- Which motion estimates perform best on the same held-out historical flights?
- Contribution relative to existing methods
- The benchmark puts established methods and a validation-fitted ensemble under one protocol.
- Potential commercial use
- Select candidate estimators for offline evaluation on a civil fleet’s own telemetry.
Computed 2026-11-06T10:25:09.902316+00:00 · reproducible scientific prototype
Measured and computed results
| model | ADE_m | FDE_m | RMSE_m | MAE_coordinate_m | coverage95 |
|---|---|---|---|---|---|
| RW | 34.795993 | 57.405282 | 41.426328 | 20.467411 | 0.96096 |
| CV | 12.743919 | 20.827194 | 22.185587 | 8.206763 | 0.90653 |
| CA | 18.129089 | 35.422055 | 29.652082 | 11.491921 | 0.883761 |
| KF | 9.121695 | 17.242098 | 15.83215 | 5.798683 | 0.904366 |
| CRW | 9.271408 | 17.240235 | 15.439684 | 5.92636 | 0.909744 |
| OU | 180.270339 | 237.539602 | 208.814684 | 116.08671 | 0.98021 |
| ENSEMBLE | 9.59961 | 17.400355 | 15.11573 | 6.119857 | 0.926349 |
Paired comparison and uncertainty
| model | reference | mean_ADE_difference_m | two_sided_exact_signflip_p | units | holm_adjusted_p |
|---|---|---|---|---|---|
| RW | CV | 22.052075 | 0.003906 | 9 | 0.023438 |
| CA | CV | 5.385171 | 0.003906 | 9 | 0.023438 |
| KF | CV | -3.622223 | 0.003906 | 9 | 0.023438 |
| CRW | CV | -3.472511 | 0.003906 | 9 | 0.023438 |
| OU | CV | 167.52642 | 0.003906 | 9 | 0.023438 |
| ENSEMBLE | CV | -3.144308 | 0.003906 | 9 | 0.023438 |
Robustness
| condition | model | ADE_m | matched_baseline_ADE_m | origins |
|---|---|---|---|---|
| context_noise2m | RW | 34.989761 | 34.795993 | 439 |
| context_noise2m | CV | 13.186904 | 12.743919 | 439 |
| context_noise2m | CA | 23.081313 | 18.129089 | 439 |
| context_noise2m | KF | 23.934084 | 9.121695 | 439 |
| context_noise2m | CRW | 23.260576 | 9.271408 | 439 |
| context_noise2m | OU | 180.268998 | 180.270339 | 439 |
| context_noise2m | ENSEMBLE | 22.686669 | 9.59961 | 439 |
| context_missing30percent | RW | 35.769462 | 34.874378 | 435 |
| context_missing30percent | CV | 12.865287 | 12.78599 | 435 |
| context_missing30percent | CA | 18.334218 | 18.112987 | 435 |
| context_missing30percent | KF | 9.243975 | 9.115594 | 435 |
| context_missing30percent | CRW | 9.504622 | 9.270341 | 435 |
| context_missing30percent | OU | 182.589058 | 179.941936 | 435 |
| context_missing30percent | ENSEMBLE | 9.830866 | 9.594352 | 435 |
Scientific result SHA-256: 1f0238e055f9f9a1d601982e68e3e6406f6148a4e768ca17fd0cdfed30427280. Numerical correctness is evaluated with independent controls and source replay; scientific validity remains bounded by source quality and model assumptions.